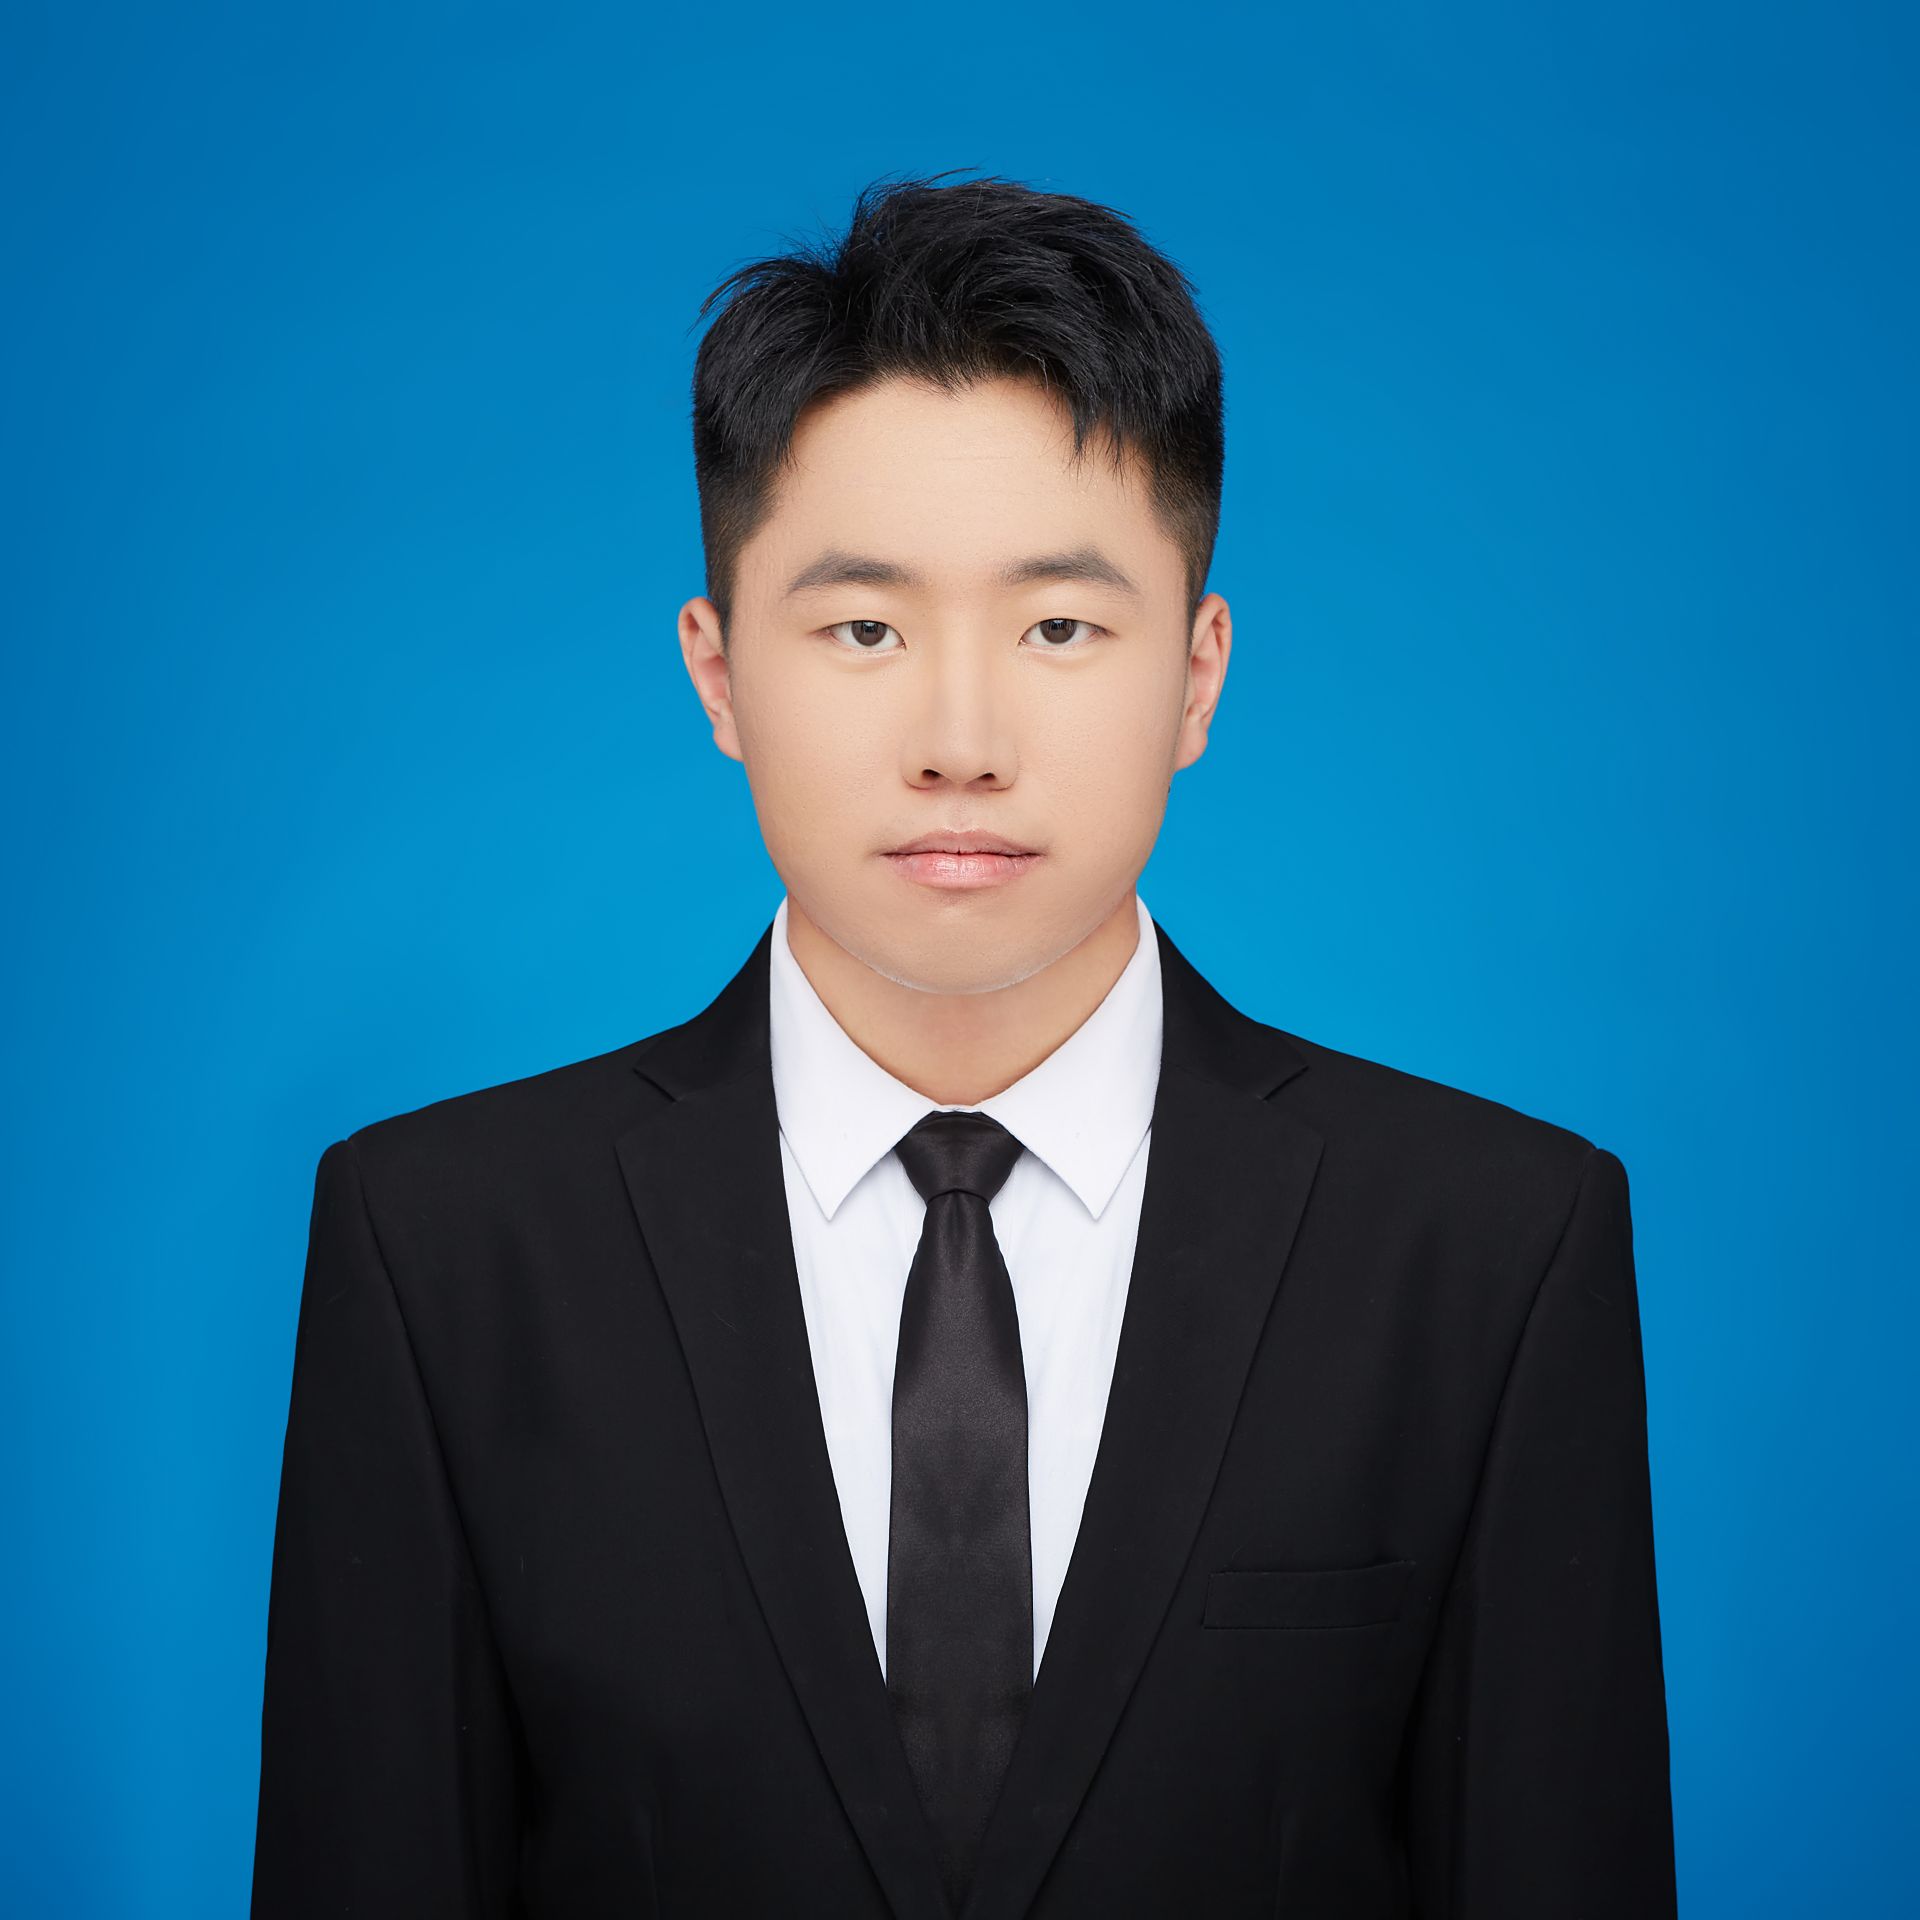
Weizheng Wang 王维政
Master of Artificial Intelligence and Machine Learning graduate
I study multimodal UAV decision evaluation, visual memory, efficient computer vision, and edge deployment. From February to August 2026, I worked remotely as a Research Assistant at Zayed University on protocol-conditioned evaluation of multimodal UAV agents.
Before Adelaide, I completed a B.Eng. in Computer Science and Technology at North China Institute of Science and Technology, where I worked on UAV monitoring, object detection, and practical perception systems.
Research interests: multimodal evaluation, visual episodic memory, efficient vision, structured pruning, and UAV/edge AI.
Selected Publications
View all-
TRIM: Dual-Budget Structured Pruning with Information-Modulated Saliency for CNN, Transformer, and Mamba Vision Models
W. Wang†, J. Wu†, Q. Tian, and L. Tian. Submitted to IEEE ICASSP 2027, 2026. Repository
-
When Retrieval Is Not Binding: A Diagnostic Benchmark for Visual Episodic Memory
W. Wang†, J. Wu†, L. Tian, and Q. Tian. Submitted to IEEE ICASSP 2027, 2026. Repository
-
A Lightweight Thermal Denoising and Occlusion-Robust Infrared Detection Model for Substation Equipment
J. Wu†, W. Wang†, Y. Niu, X. Shi, and L. Tian. IEEE ICIP, 2026. Code
† Equal contribution. Submitted manuscripts are not yet accepted.
Updates
- Submitted TRIM, visual episodic-memory diagnostics, ManiSeg, and EmergUAV-Bench to IEEE ICASSP 2027.
- Released the MulRobBench preprint; submitted to Applied Soft Computing.
- Joined Zayed University as a remote Research Assistant in February.
Research Experience
View all-
Zayed University
Co-developed MulRobBench: 3,024 UAV decision samples across 17 task-taxonomy nodes, with evaluation pipelines for 17 multimodal models.
-
Huawei MindSpore Open-Source Community
Contributed to MindNLP model integration and fine-tuning workflows for Autoformer, BEiT, and ALBERT, with attention to training stability and reproducibility.
-
Automatic Inspection and Rescue Based on Drone Nest
Developed UAV inspection pipelines using DeepSORT and YOLOv8, with ONNX export for real-time edge inference.
Education
-
University of Adelaide / Adelaide University
Master of Artificial Intelligence and Machine Learning
Completed 18 August 2026; degree conferred 7 October 2026
Testamur issued by Adelaide University -
North China Institute of Science and Technology
B.Eng. in Computer Science and Technology, GPA 4.02
Selected Honors
View all- University of Adelaide Global Citizens 30% International Scholarship
- Principal Investigator, National Undergraduate Innovation Training Program
- Second Prize, Challenge Cup Science and Technology Invention and Creation Track